
Code · 2023 · CHARGED UP
2023 Robot Code (Nova)
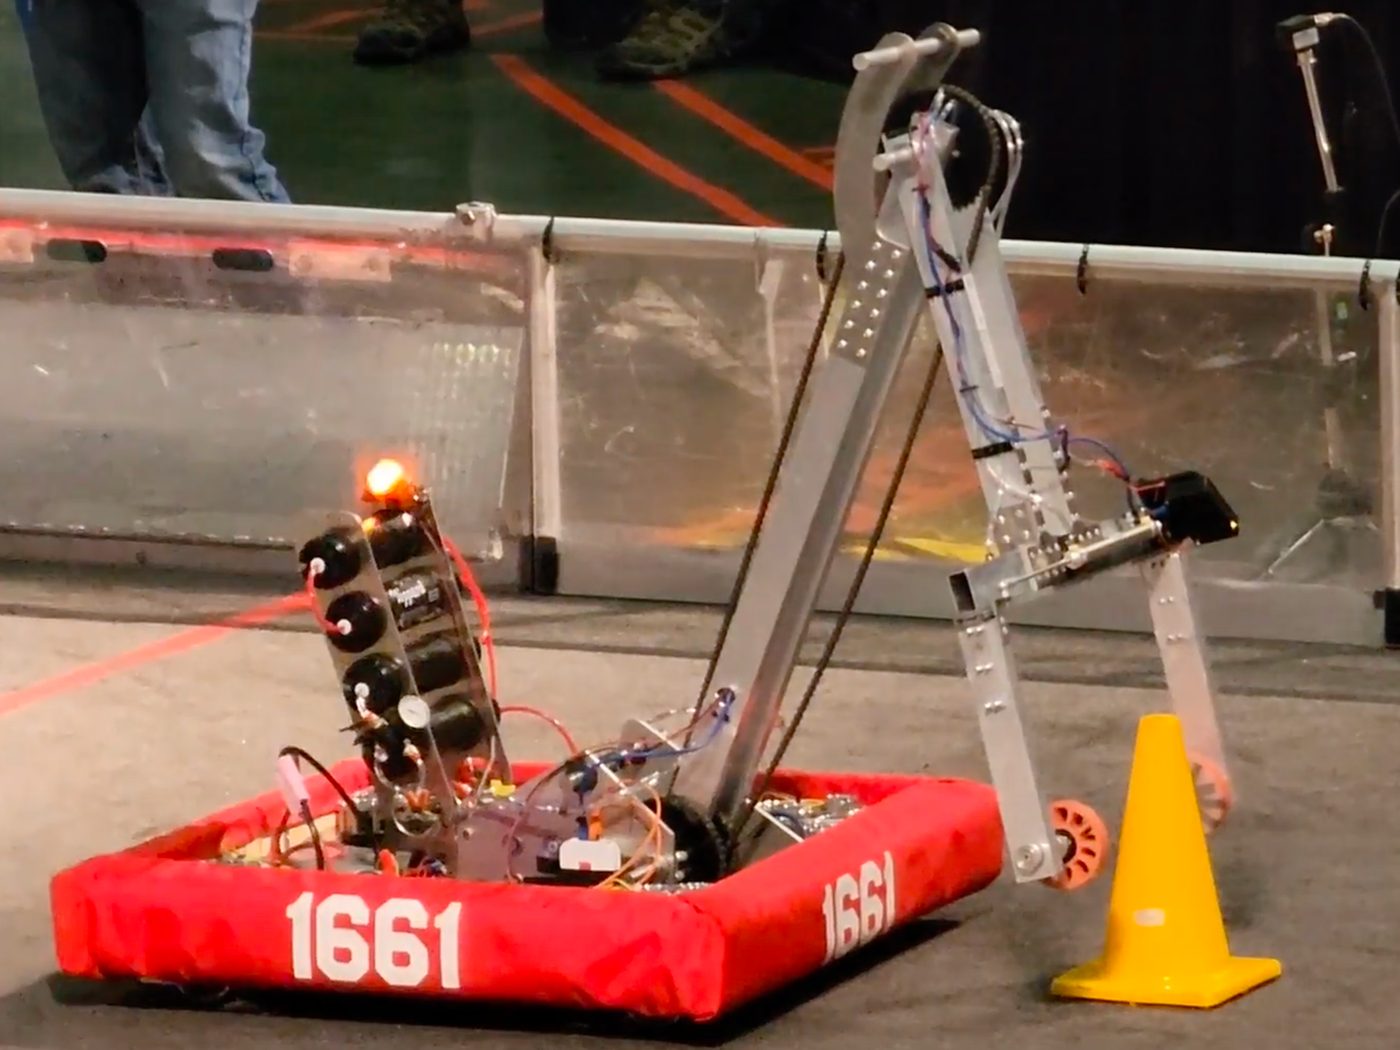
Code for Nova, our 2023 Charged Up robot, which has a tall chain-driven arm for picking up and placing game pieces. It uses a Swerve Drive Specialties swerve drivetrain.
What’s in it
1661-RobotCode-2023
- Swerve drivetrain built on the Swerve Drive Specialties library, with a NavX gyro
- Arm and claw subsystems, plus a game piece mode toggle
- Several autonomous routines, including placing a cube and then taxiing or balancing
- A small Xbox controller wrapper and a default drive command
Tech at a glance
- Language
- Java 11
- Framework
- WPILib 2023 (command-based)
- Vendor libraries
- CTRE Phoenix, NavX, SDS swerve library
Try it
Quick start
Build
./gradlew buildSimulate
./gradlew simulateJavaDeploy to a roboRIO
./gradlew deployFull instructions are in the README on GitHub.
This code is released under the MIT License, so you are welcome to learn from it and reuse it.
Want to join?
If you go to Buckley, come by the robotics room after school. We’ll find something for you to work on.